

تصميم روبوت ذاتي التوازن باستخدام الاردوينو 1
مقدمـــــة عن المشروع
بعد أن استلهمت من محركات RYNO وغيرها من الدراجات البخارية ذات التوازن الذاتي ، أردت دائمًا بناء شيء مشابه . أفكر لفترة من الوقت ، قررت بناء روبوت التوازن الذاتي باستخدام اردوينو . وبهذه الطريقة ، سأكون قادرًا على فهم المفهوم الكامن وراء كل هذه الدراجات البخارية وأيضًا معرفة كيفية عمل خوارزمية PID .
في هذا المشروع سأوثق تجربتي في بناء روبوت التوازن الذاتي . قد تكون مبتدئًا مطلقًا بدأ للتو أو ربما وصل إلى هنا بعد خيبة أمل طويلة لعدم تشغيل روبوتك . هذا المكان يهدف إلى أن يكون وجهتك النهائية . اذا هيا بنا نبدأ ……
متطلبات المشروع
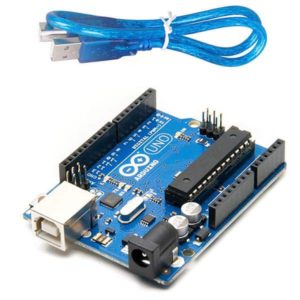
- Arduino UNO
- Geared DC motors (Yellow coloured) – 2Nos
- L298N Motor Driver Module
- MPU6050
- A pair of wheels
- 7.4V Li-ion Battery
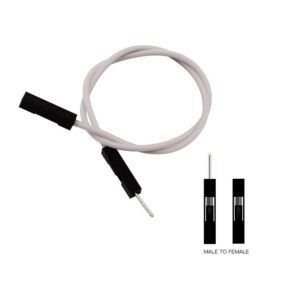
- Connecting wires
-
-
مواتير ودرايفرات, جميع المنتجات
درايفر محركات L298N Motor Driver Controller Module
لمحة سريعة
- المعنى الحالي لكل محرك.
- المبدد الحراري لأداء أفضل.
- مؤشر LED للتشغيل.
- رقاقة محرك الجسر H المزدوج: L298N.
- جهد التشغيل (VDC): 5 ~ 35
- تيار الذروة (A): 2
- التيار المستمر (A): 0-36mA
- عدد القنوات: 2
- الحماية من التيار الزائد (أ): نعم
- الحماية الحرارية: نعم
للاطلاع على فكرة مشروع تساعدك على برمجة واستخدام هذا المنتج
SKU: AA034 -
أسلاك وتوصيلات, جميع المنتجات
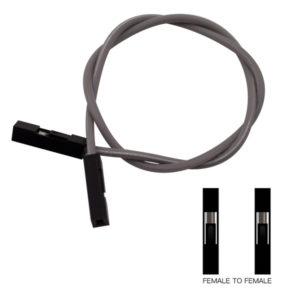
عدد 1 سلك انثى انثى 20 سم بألوان عشوائية Female to Female jumper wires
لمحة سريعة
- الطول: 200 ملم
- الوزن: 45 جم
- متوافق مع رؤوس تباعد 2.54 مم
- 1 قطعة من سلك القفز اللوني من أنثى إلى أنثى
- جودة عالية وفي حالة عمل جيدة
- متين وقابل لإعادة الاستخدام
- سهل التركيب والاستخدام
SKU: AA040 -
-
-
مواتير ودرايفرات, جميع المنتجات
محرك روبوت ذكي للسيارة يعمل بتيار مستمر من 3 إلى 6 فولت Gear Motor for robot
 مواتير ودرايفرات, جميع المنتجات
محرك روبوت ذكي للسيارة يعمل بتيار مستمر من 3 إلى 6 فولت Gear Motor for robot
:لمحة سريعة
نسبة التخفيض 1:48
تناوب السرعة 125 دورة في الدقيقة / دقيقة
الجهد: 3-6VDC
التيار: 80-150 مللي أمبير
لا توجد سرعة تحميل: 3V-125 لفة / دقيقة 5V-200 لفة / دقيقة 6V-230 لفة / دقيقة
سرعة التحميل: 3V-95 لفة / دقيقة 5V-160 لفة / دقيقة 6V-175 لفة / دقيقة
عزم الدوران الناتج: 3V-0.8kg.cm5V-1.0kg.cm6V-1.1kg.cmSKU: AD014 -
جميع المنتجات, حساسات
موديول حساس التسارع MPU-6050 Accelerometer and Gyroscope Sensor
لمحة سريعة
- رقاقة مدمجة محول 16 بت AD ، إخراج البيانات 16 بت
- رقاقة دائرة قيادة : MPU6050
- جهد التشغيل: 3-5V DC
- الاتصال: بروتوكول I2C / IIC
- نطاق الدوران: ± 250 ، 500 ، 1000 ، 2000 درجة / ثانية
- نطاق التسارع: ± 2 ± 4 ± 8 ± 16 جم
SKU: AB081





طريقة العمل والتوصيل
يتم التوصيل وفقا للمخطط أدناه .

بمجرد أن تكون كل التوصيلات جاهزًا ، يمكنك تحميل الكود على لوحة الاردوينو الخاصة بك . قم بتشغيل وافتح الشاشة التسلسلية ، إذا كان بإمكان الاردوينو التواصل مع MPU6050 بنجاح وإذا كان كل شيء يعمل كما هو متوقع ، فسترى الشاشة التالية .

هنا نرى قيم المدخلات والمخرجات لخوارزمية PID في تنسيق الإدخال => الإخراج. إذا كان الروبوت متوازنًا تمامًا ، فستكون قيمة الإخراج هي 0. وتكون قيمة الإدخال هي القيمة الحالية من جهاز استشعار MPU6050 . تمثل الحرف “F” أن الروبوت يسير للأمام و “R” يمثل السير في الاتجاه المعاكس .
خلال المراحل الأولية لمعرف PID ، أوصي بترك كابل الاردوينو الخاص بك متصلاً بالروبوت بحيث يمكنك مراقبة قيم المدخلات والمخرجات بسهولة كما سيكون من السهل تصحيح وتحميل برنامجك لقيم Kp و Ki و Kd .
الكـــــــــــود البرمجي
لتحميل الكود البرمجي اضغط هنا
#include "I2Cdev.h"
#include <PID_v1.h>
#include "MPU6050_6Axis_MotionApps20.h"
MPU6050 mpu;

// MPU control/status vars
bool dmpReady = false;  // set true if DMP init was successful
uint8_t mpuIntStatus;   // holds actual interrupt status byte from MPU
uint8_t devStatus;      // return status after each device operation (0 = success, !0 = error)
uint16_t packetSize;    // expected DMP packet size (default is 42 bytes)
uint16_t fifoCount;     // count of all bytes currently in FIFO
uint8_t fifoBuffer[64]; // FIFO storage buffer

// orientation/motion vars
Quaternion q;           // [w, x, y, z]         quaternion container
VectorFloat gravity;    // [x, y, z]            gravity vector
float ypr[3];           // [yaw, pitch, roll]   yaw/pitch/roll container and gravity vector


/*********Tune these 4 values for your BOT*********/
double setpoint= 176; //set the value when the bot is perpendicular to ground using serial monitor.
//Read the project documentation on circuitdigest.com to learn how to set these values
double Kp = 21; //Set this first
double Kd = 0.8; //Set this secound
double Ki = 140; //Finally set this
/******End of values setting*********/

double input, output;
PID pid(&input, &output, &setpoint, Kp, Ki, Kd, DIRECT);


volatile bool mpuInterrupt = false;     // indicates whether MPU interrupt pin has gone high
void dmpDataReady()
{
    mpuInterrupt = true;
}

void setup() {
  Serial.begin(115200);

  // initialize device
    Serial.println(F("Initializing I2C devices..."));
    mpu.initialize();

     // verify connection
    Serial.println(F("Testing device connections..."));
    Serial.println(mpu.testConnection() ? F("MPU6050 connection successful") : F("MPU6050 connection failed"));

    // load and configure the DMP
    devStatus = mpu.dmpInitialize();


    // supply your own gyro offsets here, scaled for min sensitivity
    mpu.setXGyroOffset(220);
    mpu.setYGyroOffset(76);
    mpu.setZGyroOffset(-85);
    mpu.setZAccelOffset(1688);

      // make sure it worked (returns 0 if so)
    if (devStatus == 0)
    {
        // turn on the DMP, now that it's ready
        Serial.println(F("Enabling DMP..."));
        mpu.setDMPEnabled(true);

        // enable Arduino interrupt detection
        Serial.println(F("Enabling interrupt detection (Arduino external interrupt 0)..."));
        attachInterrupt(0, dmpDataReady, RISING);
        mpuIntStatus = mpu.getIntStatus();

        // set our DMP Ready flag so the main loop() function knows it's okay to use it
        Serial.println(F("DMP ready! Waiting for first interrupt..."));
        dmpReady = true;

        // get expected DMP packet size for later comparison
        packetSize = mpu.dmpGetFIFOPacketSize();

        //setup PID
        pid.SetMode(AUTOMATIC);
        pid.SetSampleTime(10);
        pid.SetOutputLimits(-255, 255);
    }
    else
    {
        // ERROR!
        // 1 = initial memory load failed
        // 2 = DMP configuration updates failed
        // (if it's going to break, usually the code will be 1)
        Serial.print(F("DMP Initialization failed (code "));
        Serial.print(devStatus);
        Serial.println(F(")"));
    }

//Initialise the Motor outpu pins
    pinMode (6, OUTPUT);
    pinMode (9, OUTPUT);
    pinMode (10, OUTPUT);
    pinMode (11, OUTPUT);

//By default turn off both the motors
    analogWrite(6,LOW);
    analogWrite(9,LOW);
    analogWrite(10,LOW);
    analogWrite(11,LOW);
}


void loop() {

    // if programming failed, don't try to do anything
    if (!dmpReady) return;

    // wait for MPU interrupt or extra packet(s) available
    while (!mpuInterrupt && fifoCount < packetSize)
    {
        //no mpu data - performing PID calculations and output to motors
        pid.Compute();

        //Print the value of Input and Output on serial monitor to check how it is working.
        Serial.print(input); Serial.print(" =>"); Serial.println(output);

        if (input>150 && input<200){//If the Bot is falling

        if (output>0) //Falling towards front
        Forward(); //Rotate the wheels forward
        else if (output<0) //Falling towards back
        Reverse(); //Rotate the wheels backward
        }
        else //If Bot not falling
        Stop(); //Hold the wheels still

    }

    // reset interrupt flag and get INT_STATUS byte
    mpuInterrupt = false;
    mpuIntStatus = mpu.getIntStatus();

    // get current FIFO count
    fifoCount = mpu.getFIFOCount();

    // check for overflow (this should never happen unless our code is too inefficient)
    if ((mpuIntStatus & 0x10) || fifoCount == 1024)
    {
        // reset so we can continue cleanly
        mpu.resetFIFO();
        Serial.println(F("FIFO overflow!"));

    // otherwise, check for DMP data ready interrupt (this should happen frequently)
    }
    else if (mpuIntStatus & 0x02)
    {
        // wait for correct available data length, should be a VERY short wait
        while (fifoCount < packetSize) fifoCount = mpu.getFIFOCount();

        // read a packet from FIFO
        mpu.getFIFOBytes(fifoBuffer, packetSize);

        // track FIFO count here in case there is > 1 packet available
        // (this lets us immediately read more without waiting for an interrupt)
        fifoCount -= packetSize;

        mpu.dmpGetQuaternion(&q, fifoBuffer); //get value for q
        mpu.dmpGetGravity(&gravity, &q); //get value for gravity
        mpu.dmpGetYawPitchRoll(ypr, &q, &gravity); //get value for ypr

        input = ypr[1] * 180/M_PI + 180;

   }
}

void Forward() //Code to rotate the wheel forward
{
    analogWrite(6,output);
    analogWrite(9,0);
    analogWrite(10,output);
    analogWrite(11,0);
    Serial.print("F"); //Debugging information
}

void Reverse() //Code to rotate the wheel Backward
{
    analogWrite(6,0);
    analogWrite(9,output*-1);
    analogWrite(10,0);
    analogWrite(11,output*-1);
    Serial.print("R");
}

void Stop() //Code to stop both the wheels
{
    analogWrite(6,0);
    analogWrite(9,0);
    analogWrite(10,0);
    analogWrite(11,0);
    Serial.print("S");
}
شكرا جزيلا الى هذه المعلومات جزاكم الله خير الجزاء لقد انقذتني قبل موعد مناقشتي❤️❤️❤️